Products

Robots and extensions for education and research. Detailed documentation, examples and software are available on the wiki.

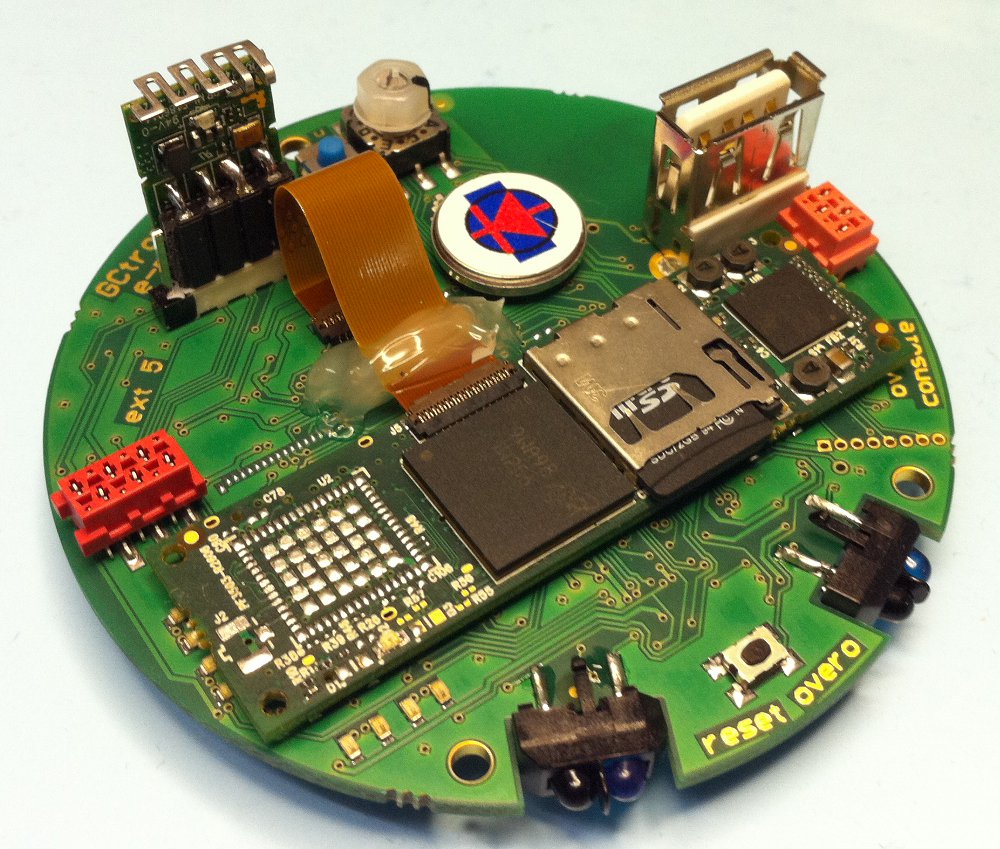
e-puck2

Educational and research mini mobile robot

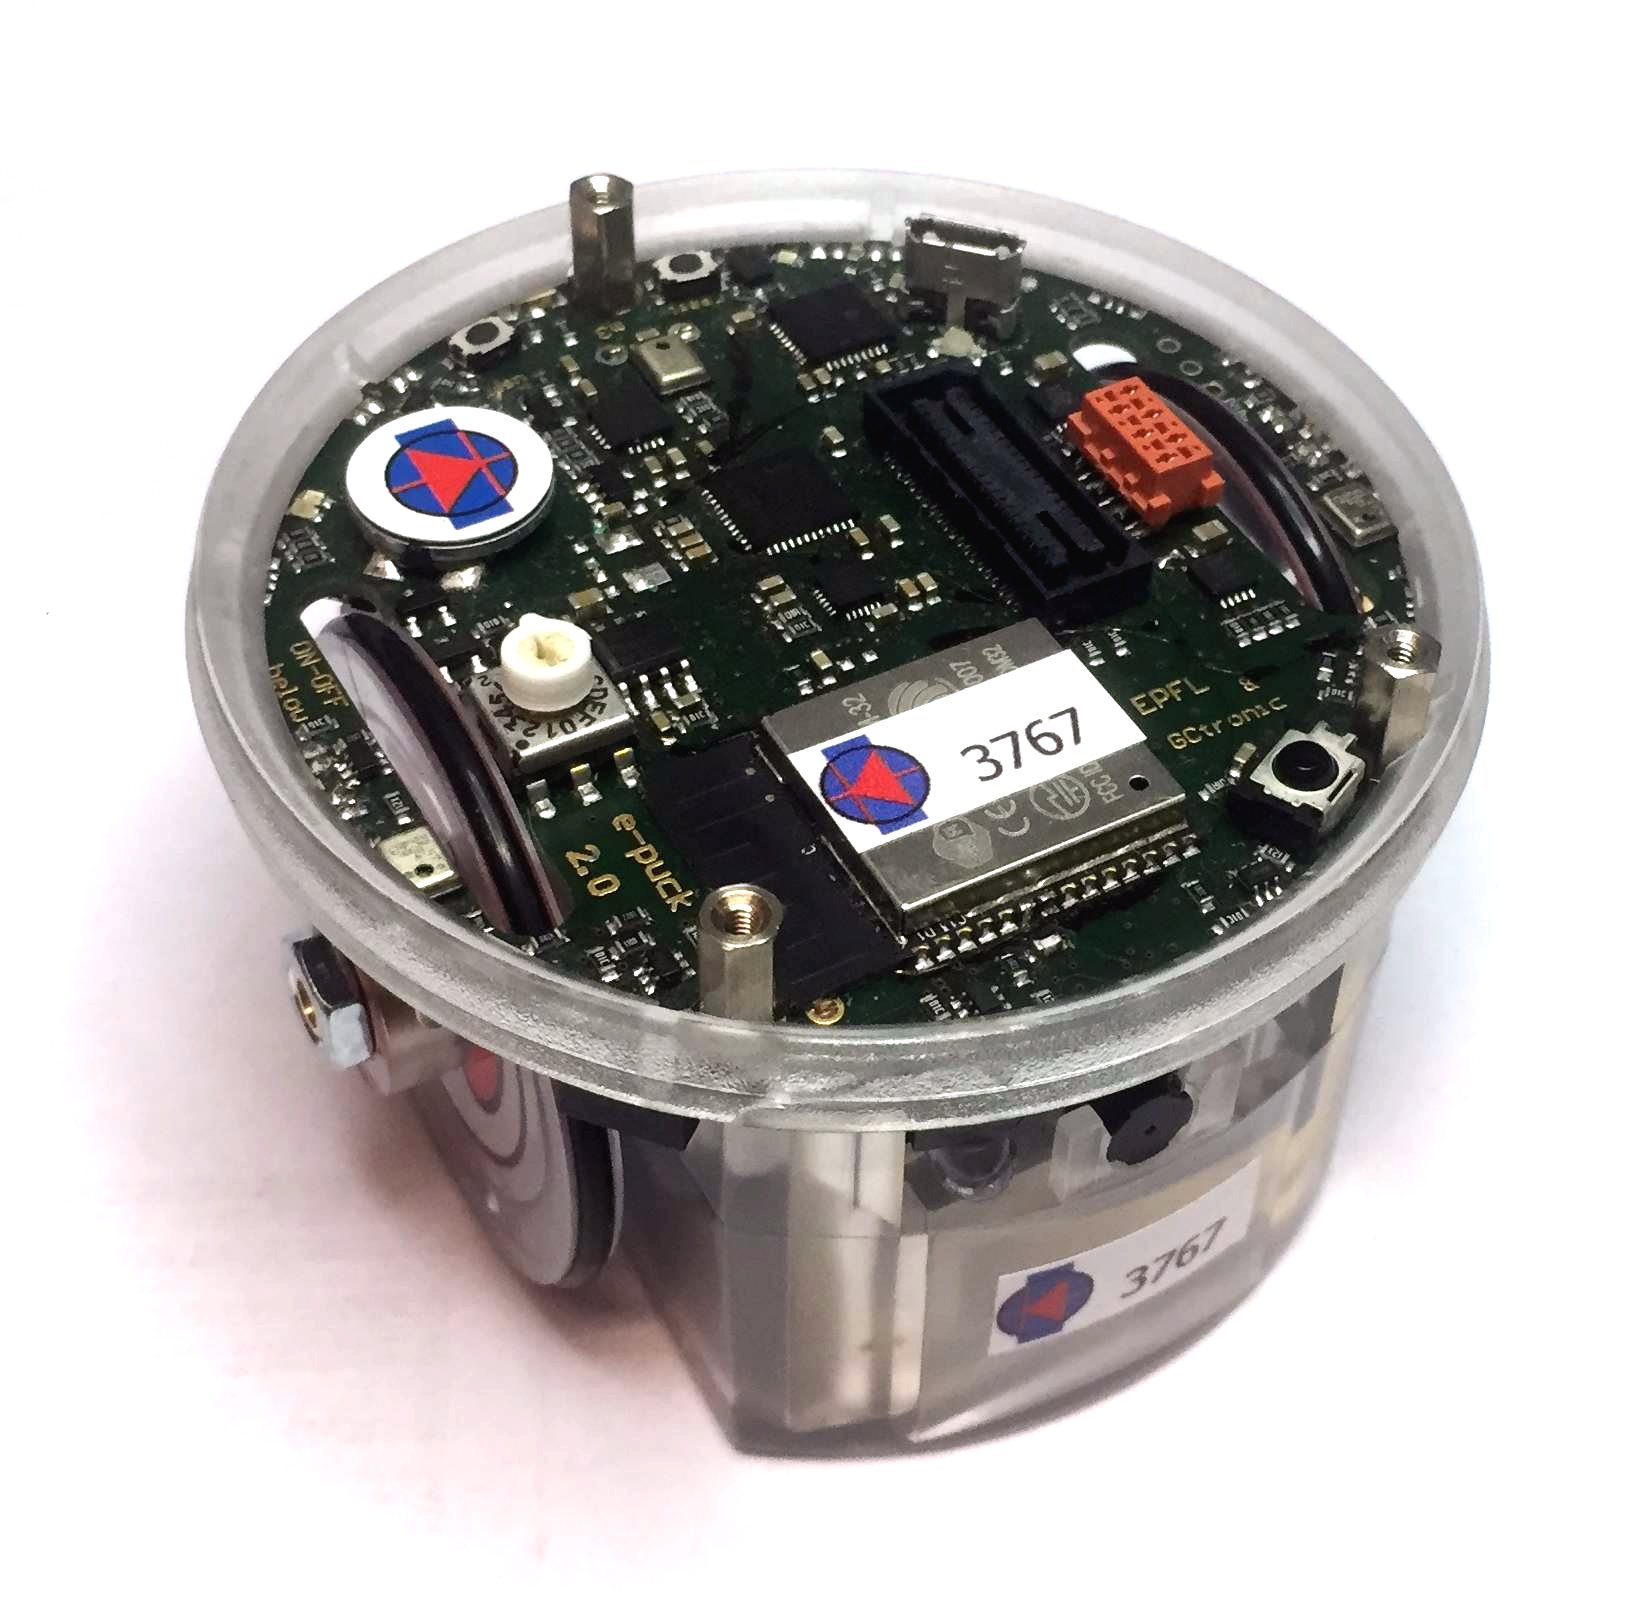
Evolution of the e-puck miniature educational robot developed at EPFL. Maintained compatibility with e-puck, faster processor and more memory, additional sensors (Time of Flight distance sensor, magnetometer, front microphone), additional wireless support (WiFi and BLE), onboard debugger, USB charging (no external charger required), micro SD support. Extendable.

Elisa-3

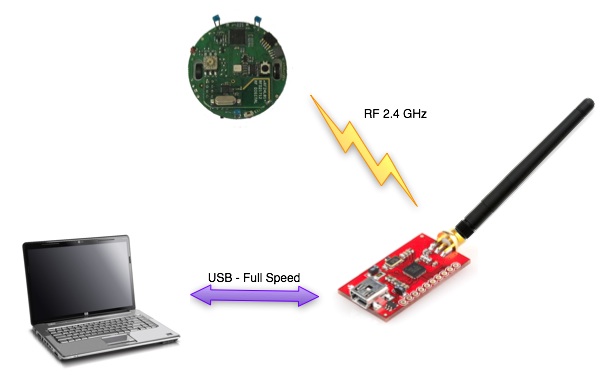
Miniature swarm robot, 5 cm

Miniature swarm robot. Diameter 5 cm. Auto recharge, fast radio, 8 proximity, 4 ground, 3D accelerometer, top RGB LED with diffuser. Magnetic wheels available to move also on vertical walls.

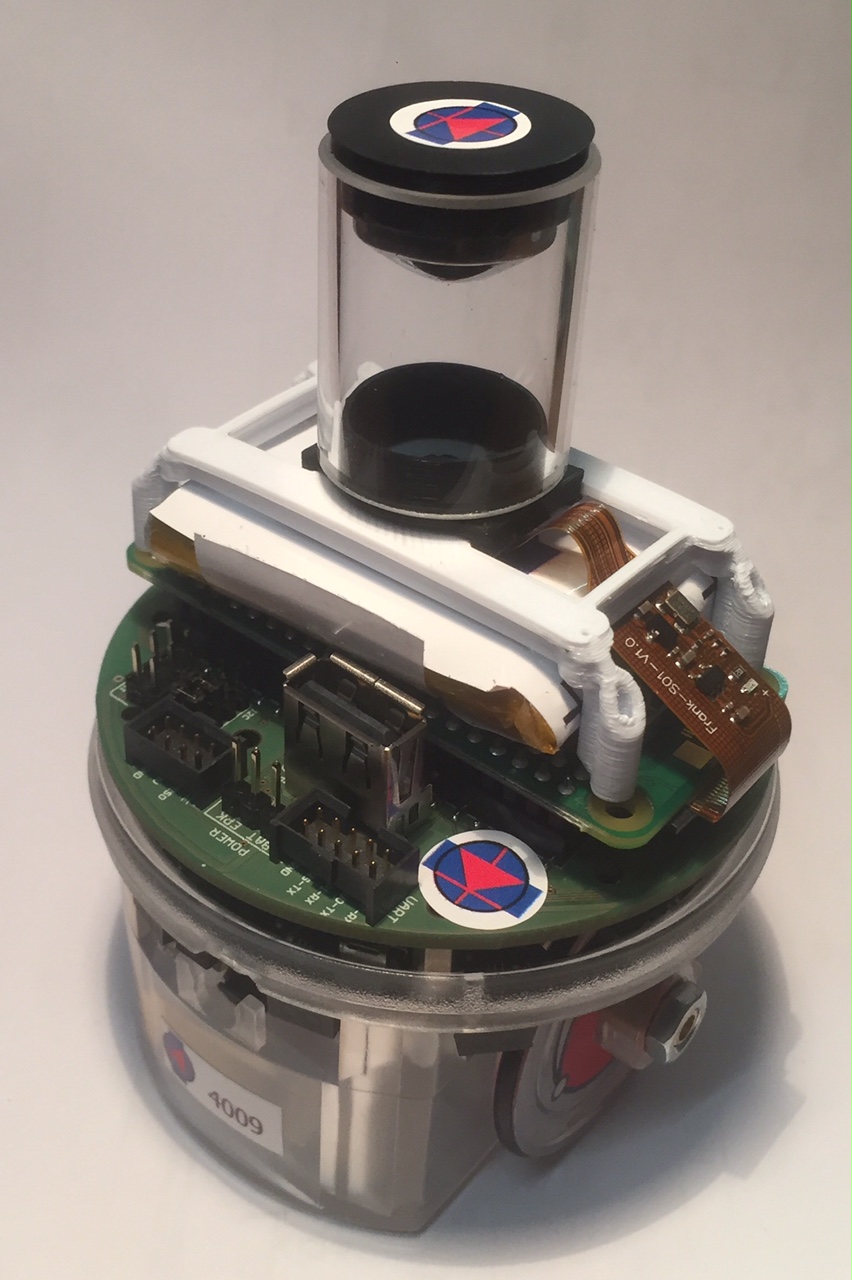
Pi-puck and extensions

Linux and Raspberry Pi on the e-puck

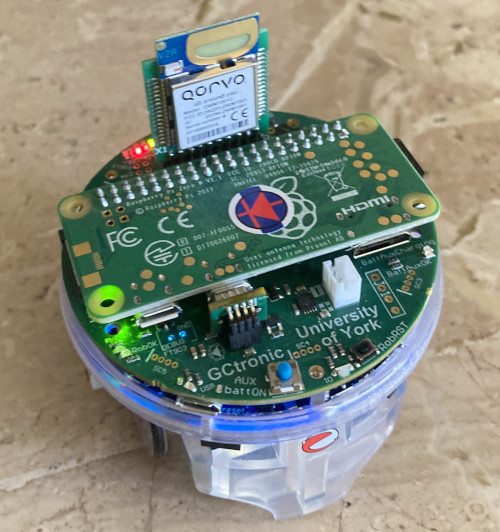
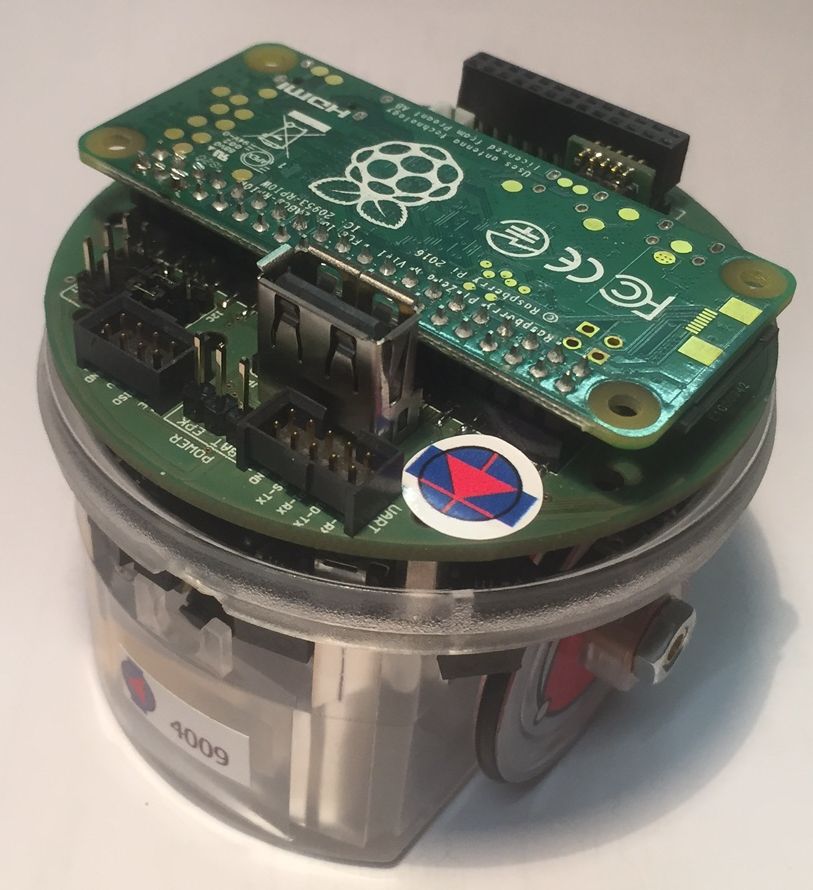
Pi-puck brings a Raspberry Pi Zero W / Zero 2 W on top of the e-puck and e-puck2 robots. It can be combined with the Omnivision V3 360° camera, the Ultra Wide Band indoor positioning module, an OLED display and the charging wall.

boat-bot

Unmanned surface vehicle for research

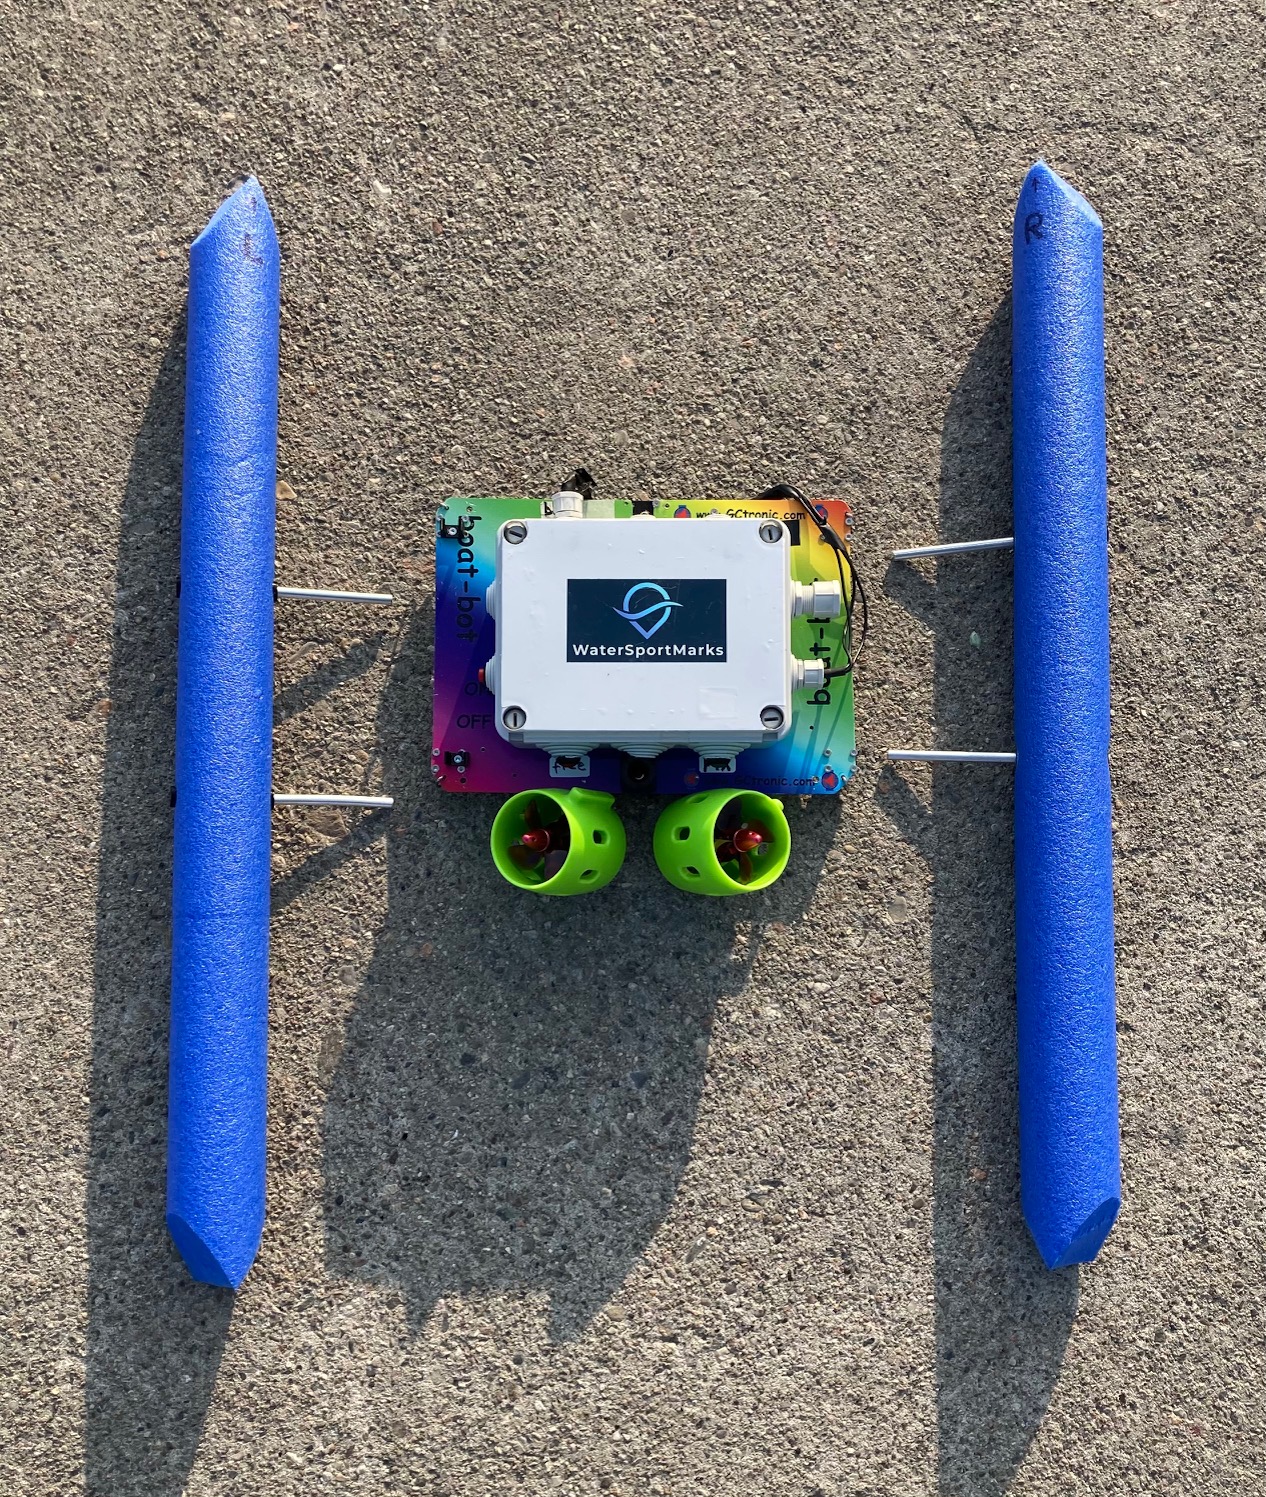
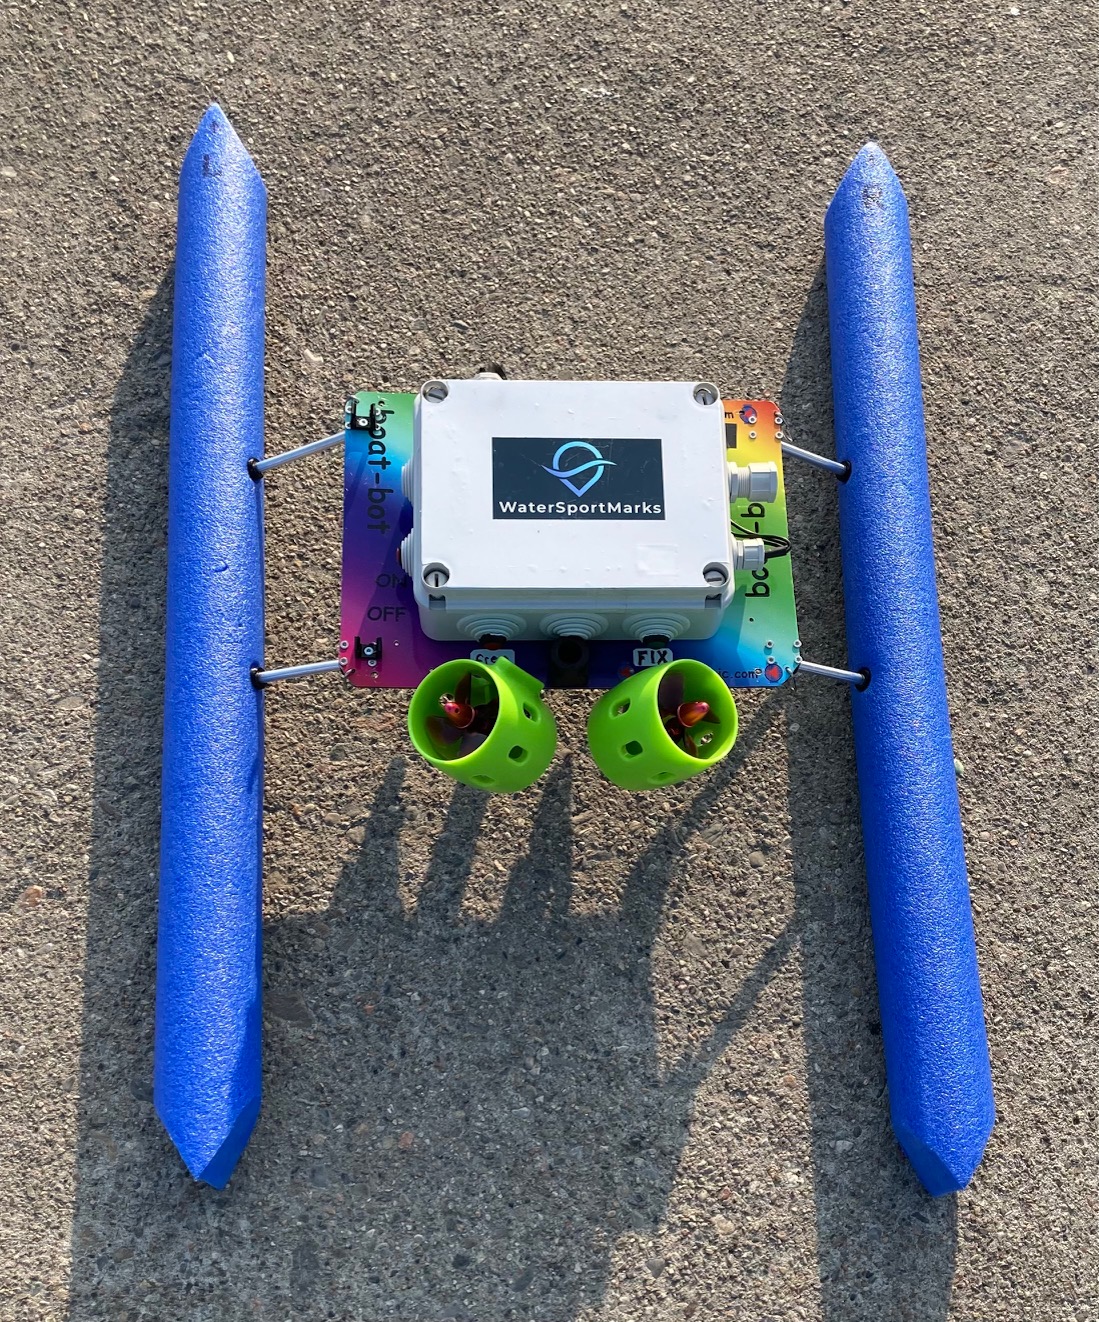
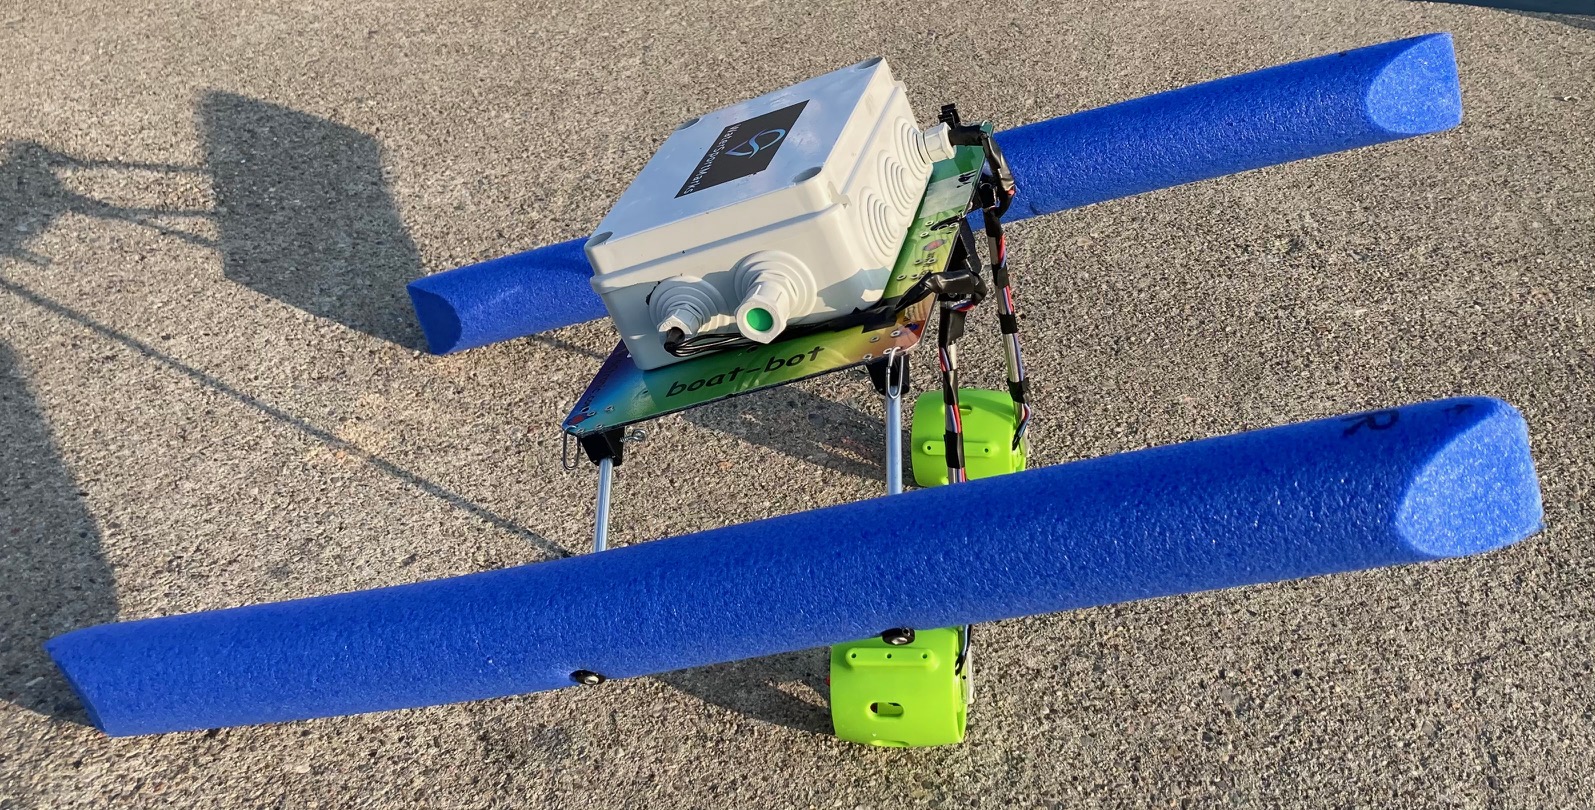
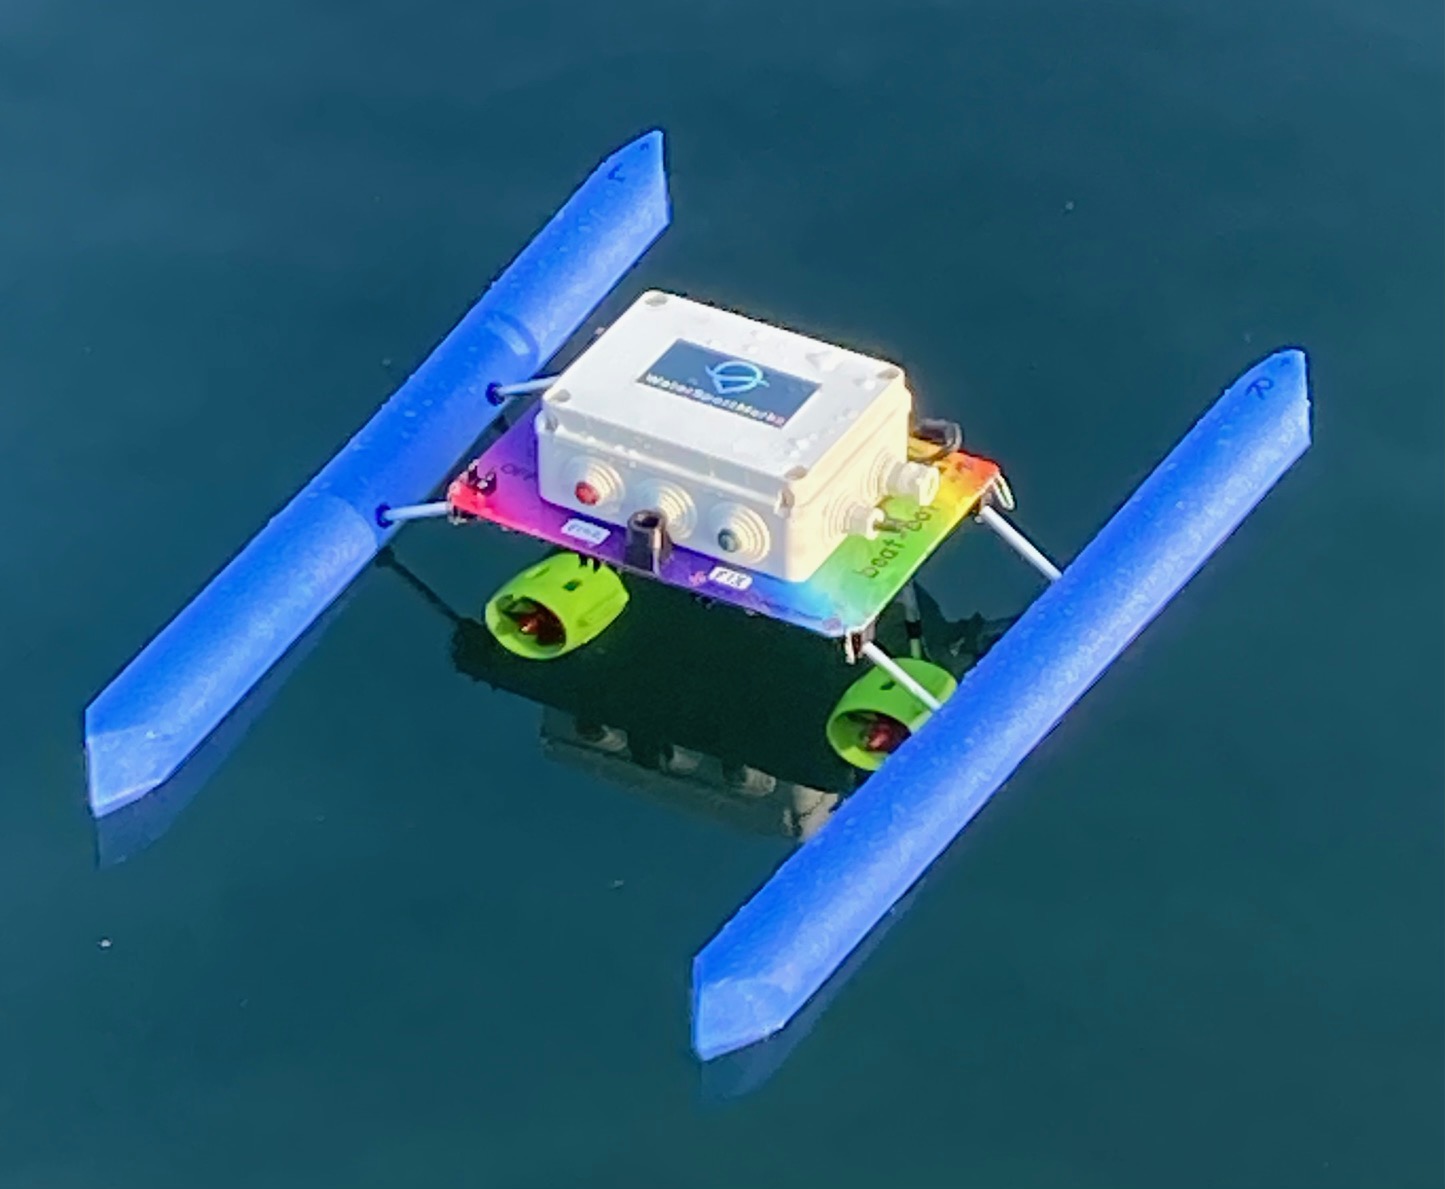
Boat-bot is a research and educational robot built as a small catamaran of less than 2 kg. Controlled by a Raspberry Pi, it has a GPS, a full 9D IMU, an Arduino, 2 motor controllers, a speaker, and more.

Autonomous Robot Painting

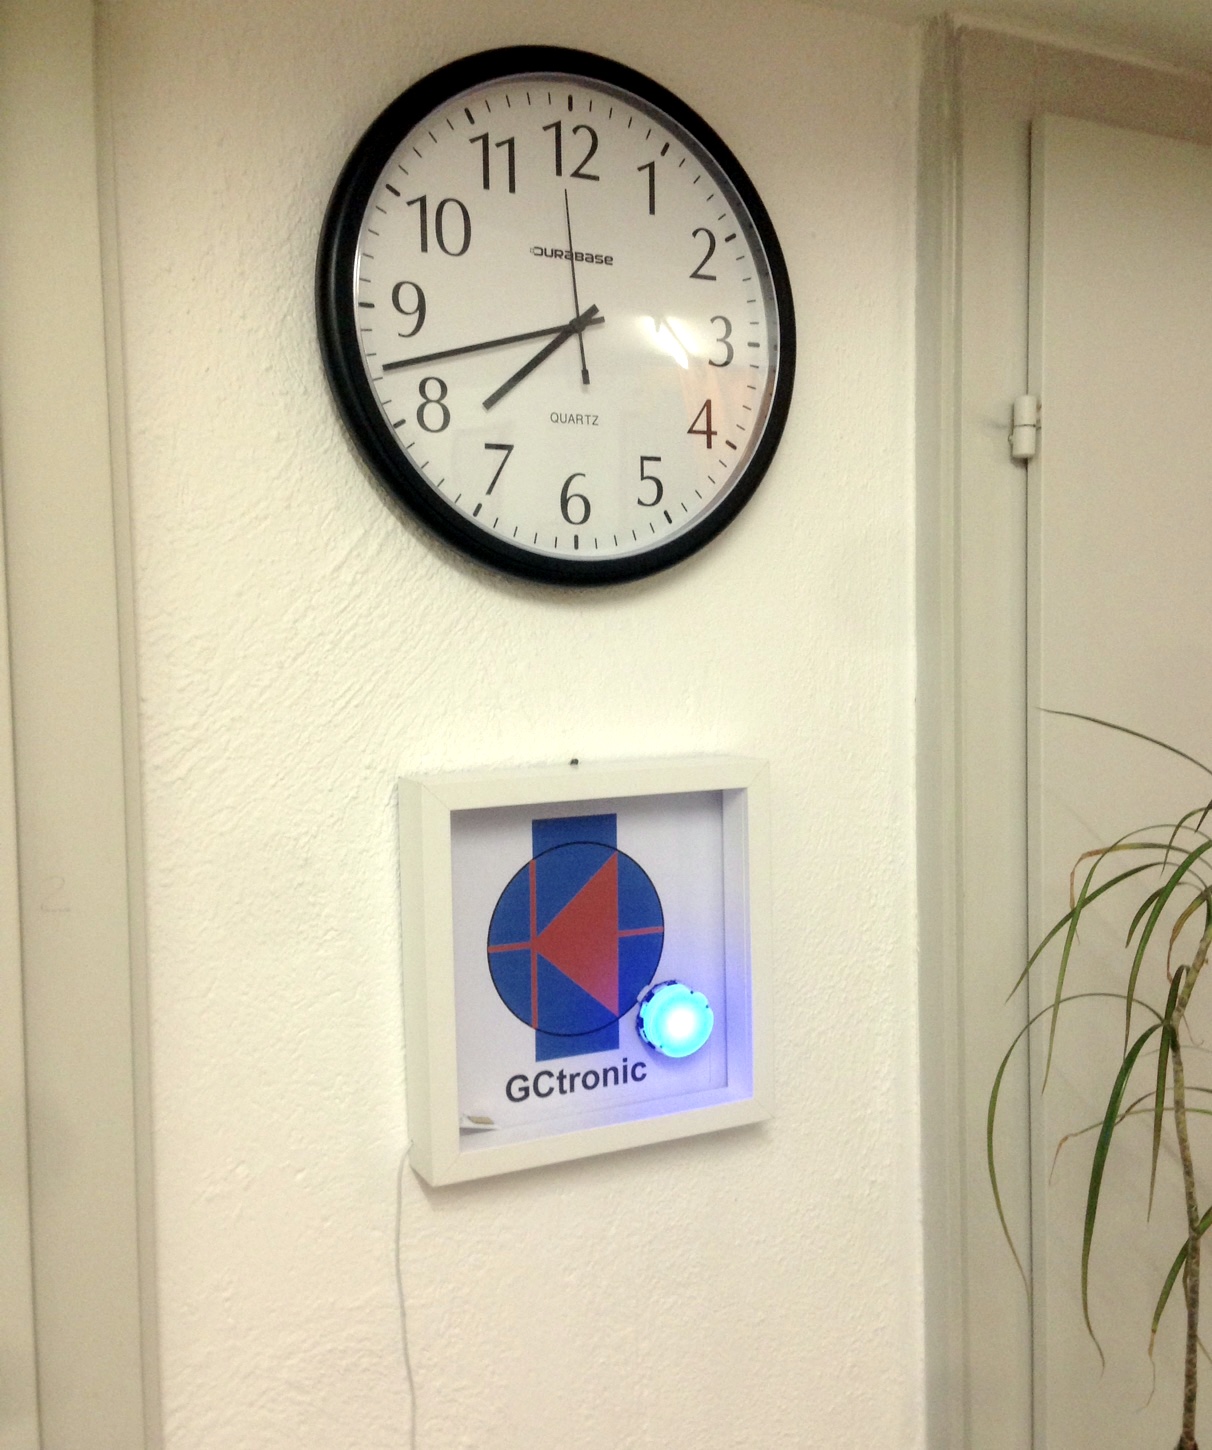
Elisa-3 living in a picture frame

Picture frame equipped with the Elisa-3 robot performing artistic animations by exploiting its onboard sensors.

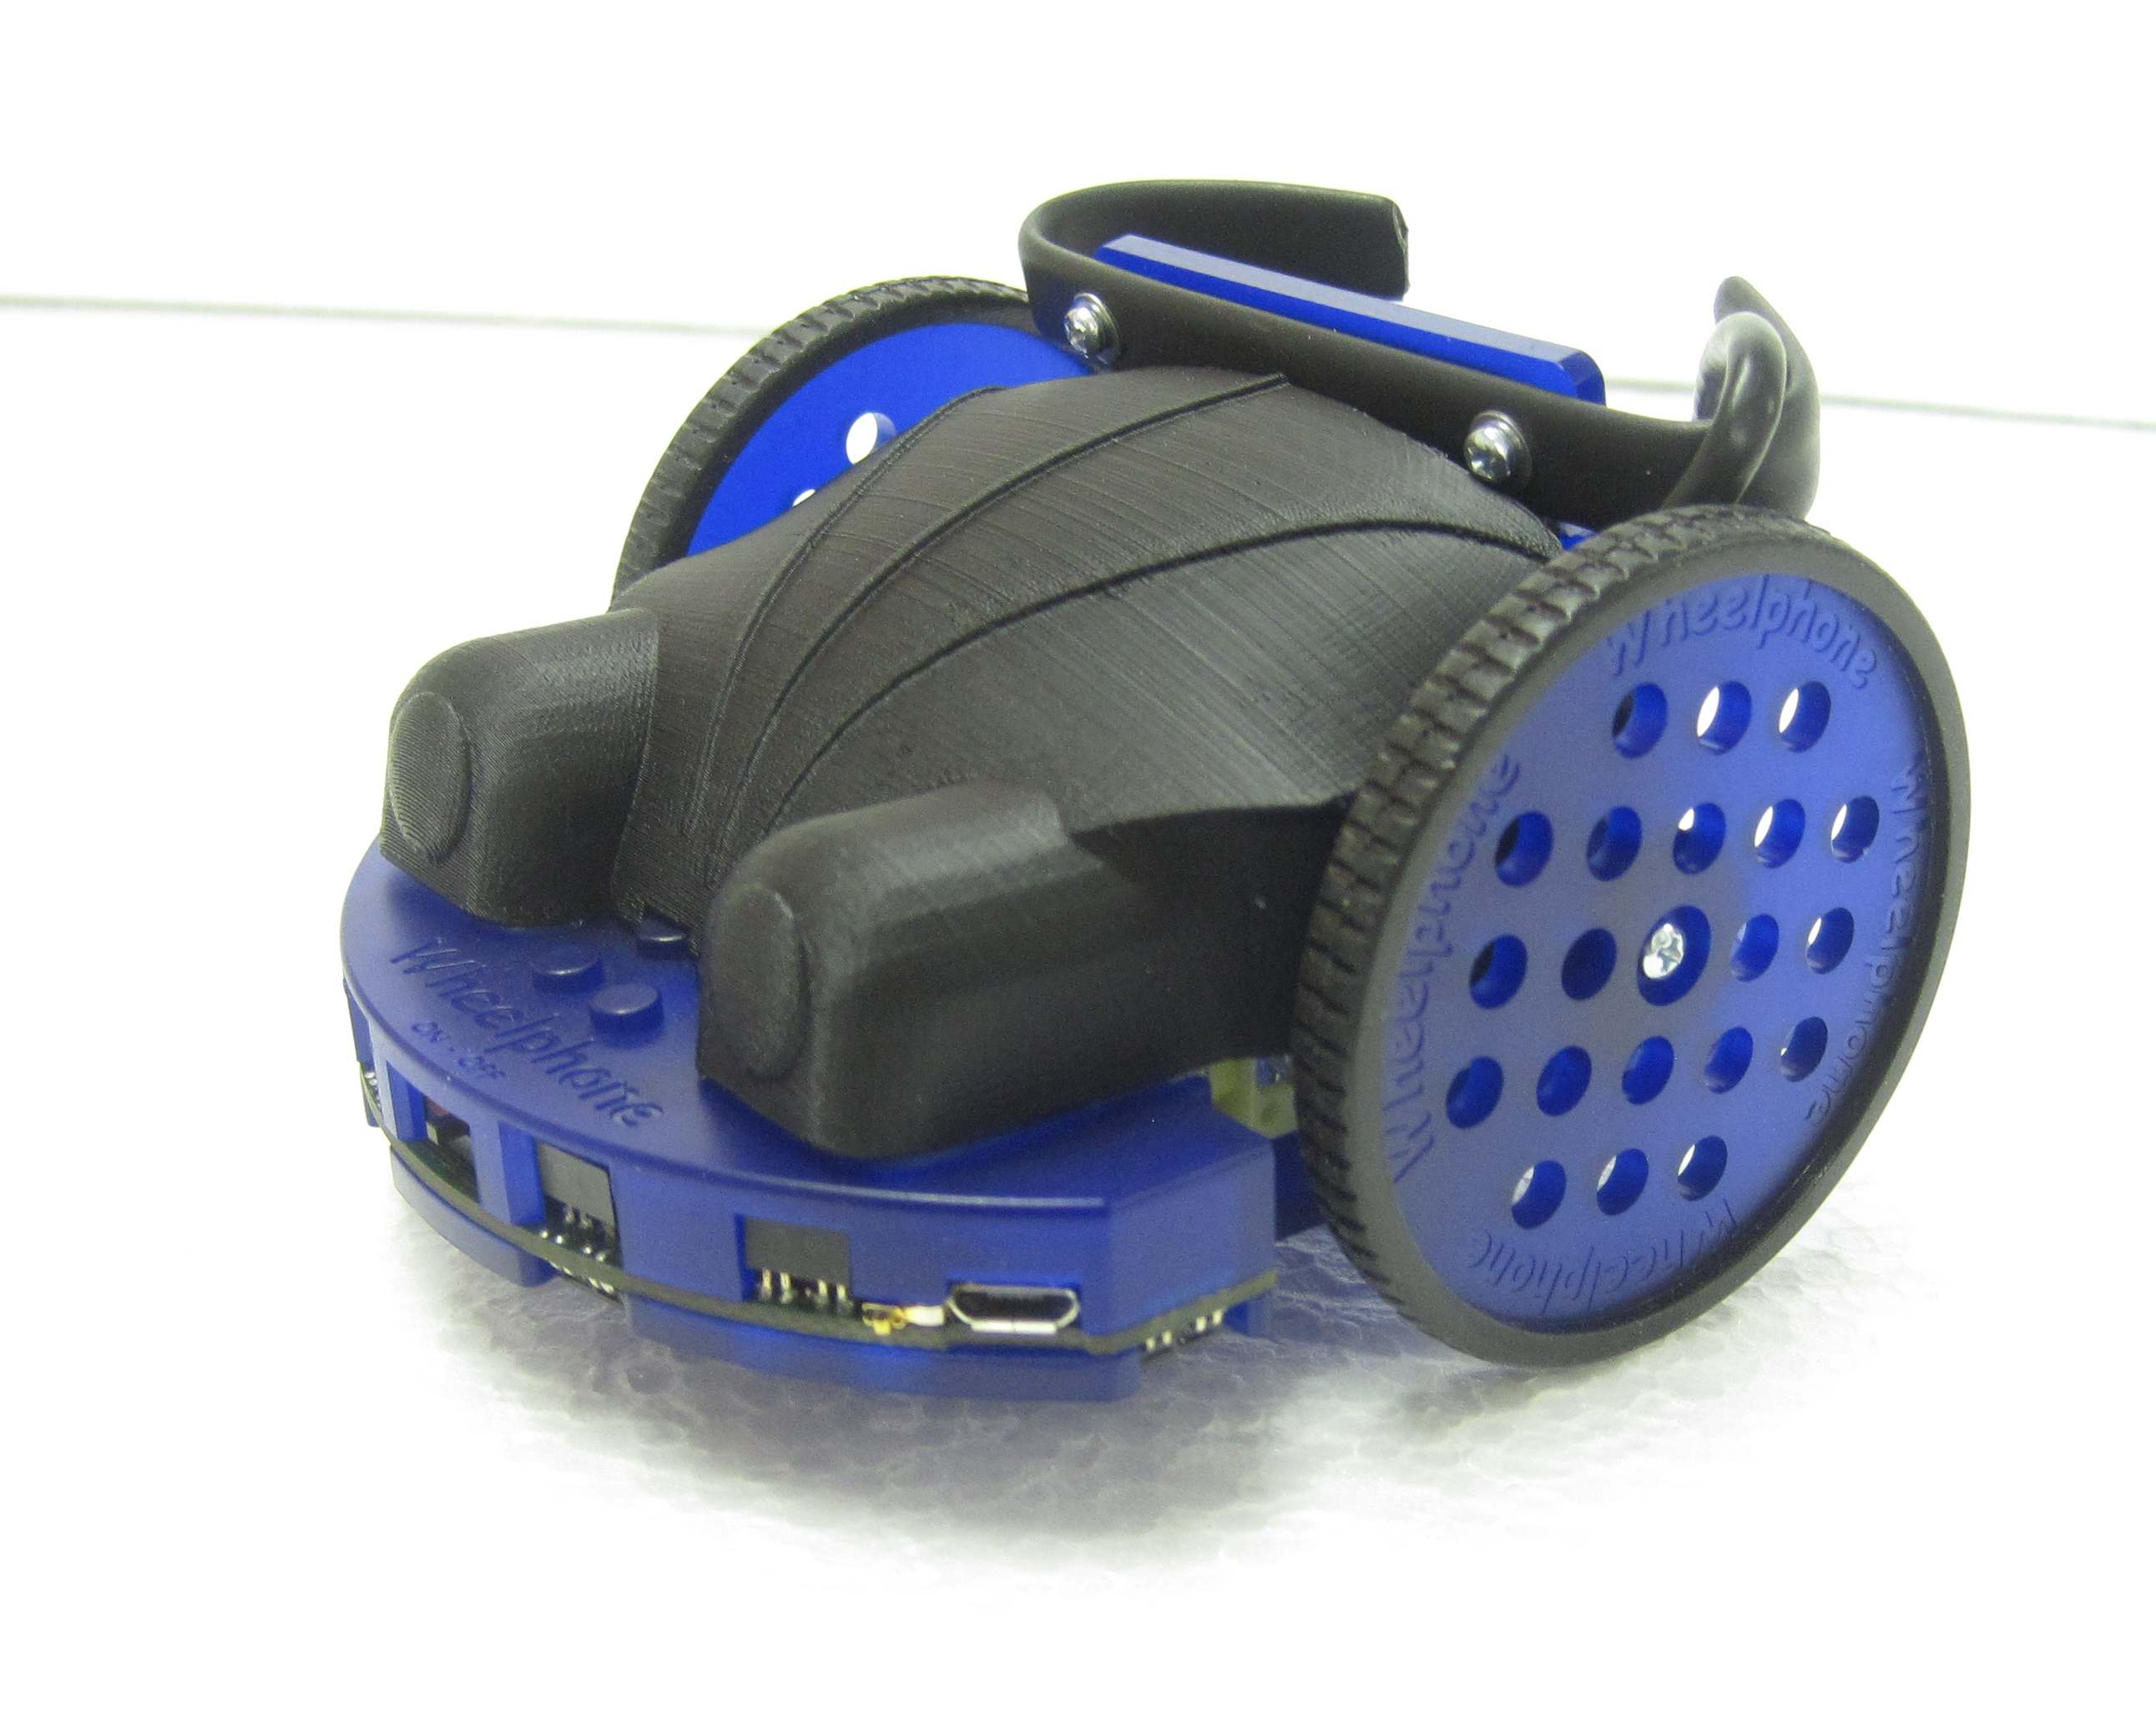
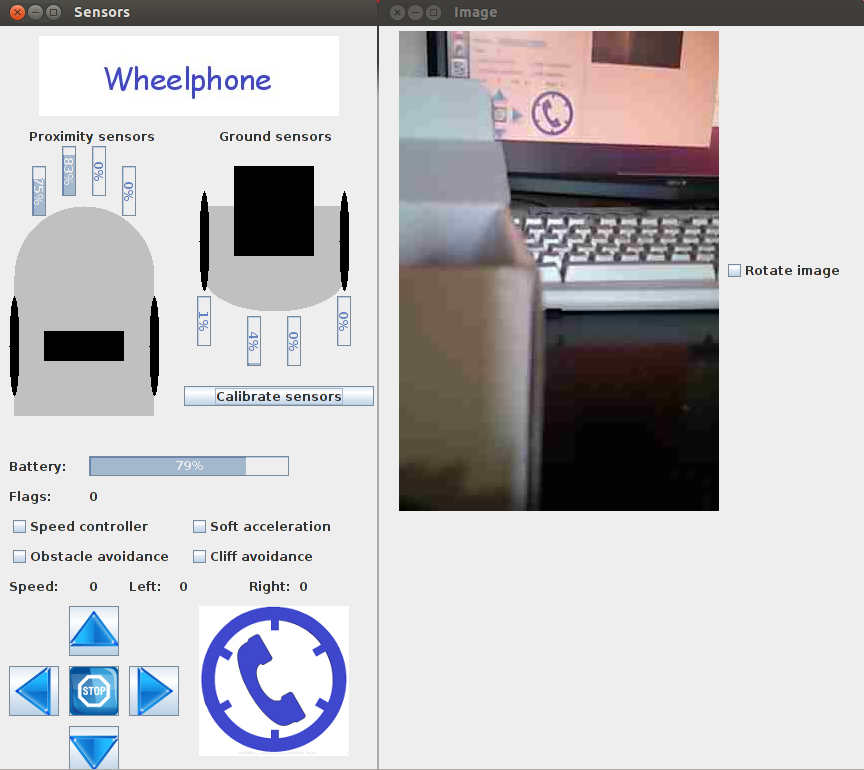
Wheelphone

Mobile phone robotic platform

Mobile phone robotic platform compatible with both Android and iPhone. 4 proximity, 4 ground sensors, auto recharge.

End of life

e-puck

The original EPFL educational robot

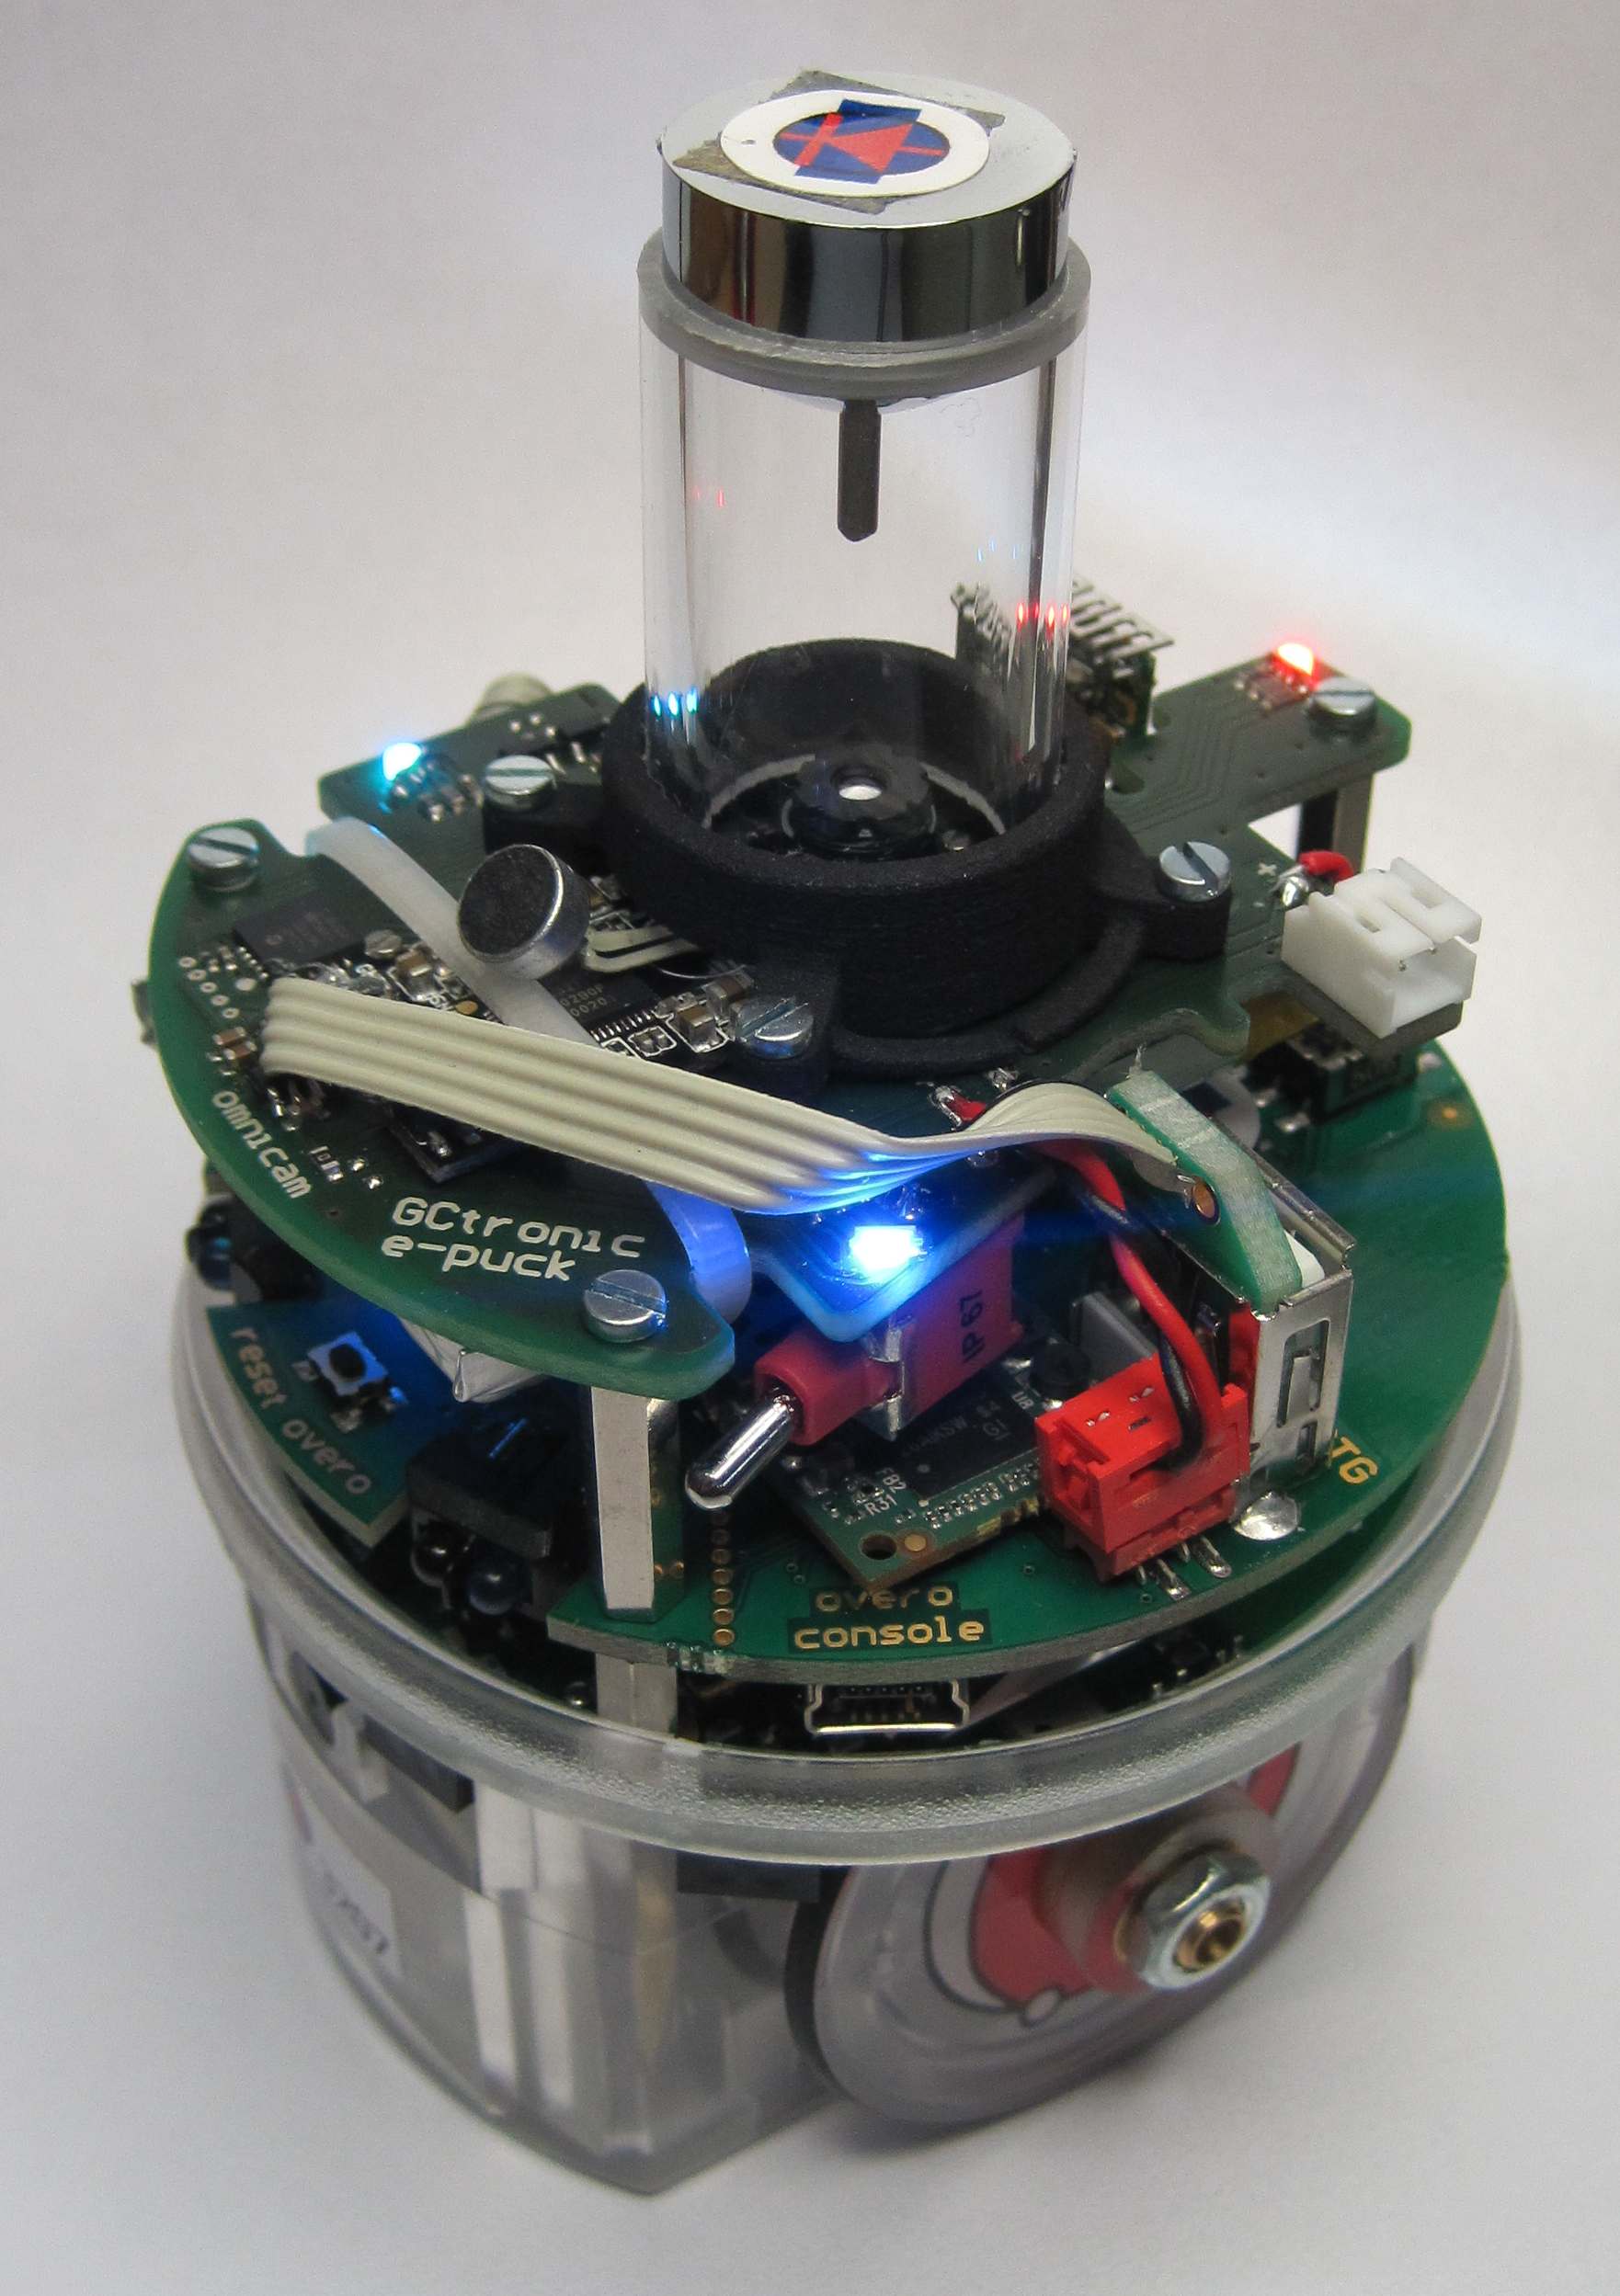
Miniature educational robot developed at EPFL. Ø 7 cm. Open software, open hardware. 8 proximity, VGA camera, 3D accelerometer, 3 microphones, Bluetooth. Extendable. The e-puck is no more produced: its successor is the e-puck2.

Webots

Robot simulator

Physics based simulator. Well integrated with e-puck and e-puck2: the robot can be simulated, remote controlled or cross compiled.